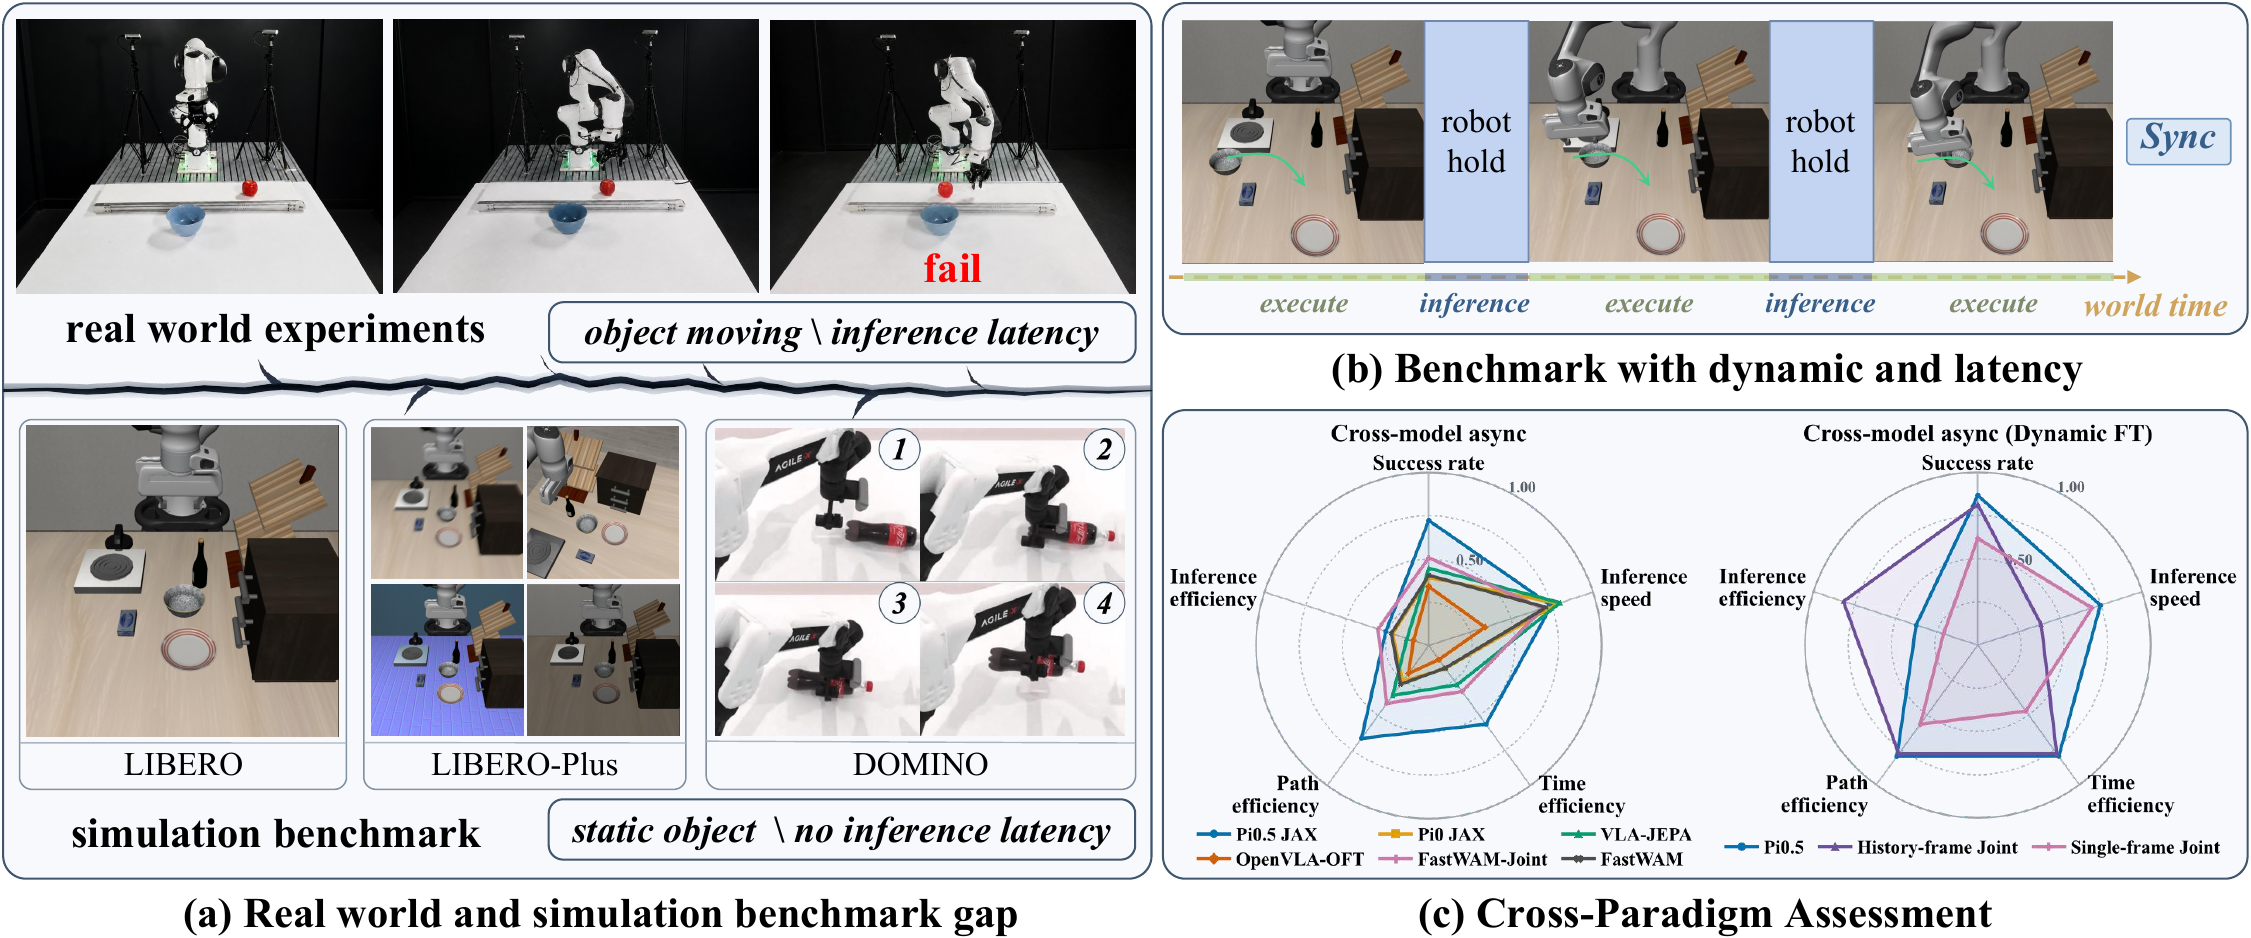
A controlled extension of LIBERO for moving-object manipulation. Study how object motion, inference latency, and action execution shape robot performance.
Object motion and inference latency, evaluated together.
01 / Findings
Main results
Three complementary views of dynamic manipulation.
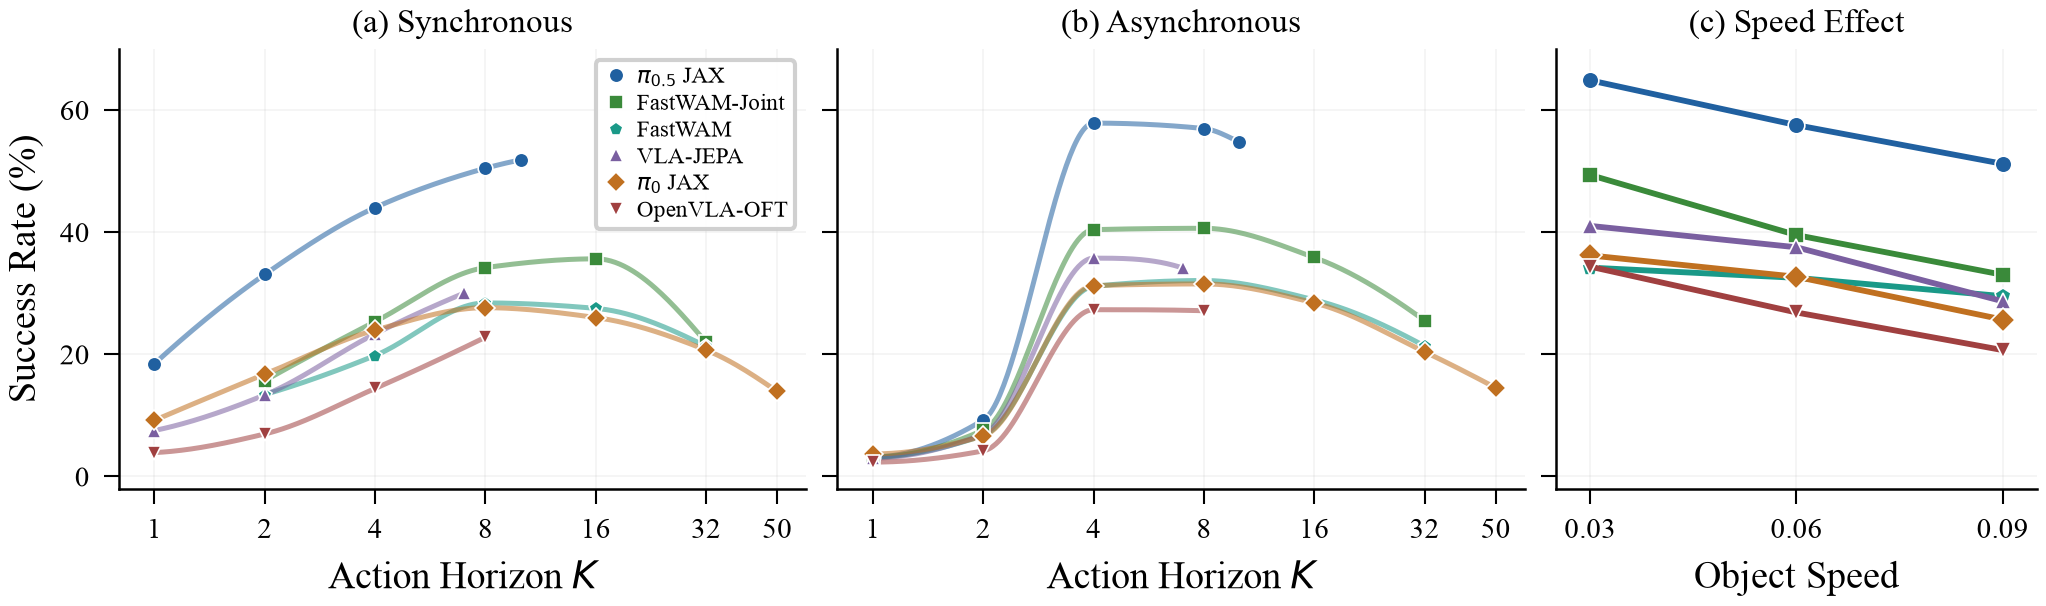
Pretrained policies
All six policies degrade as target speed increases, but their sensitivity and best measured action horizons differ.
Click the figure to enlarge ↗
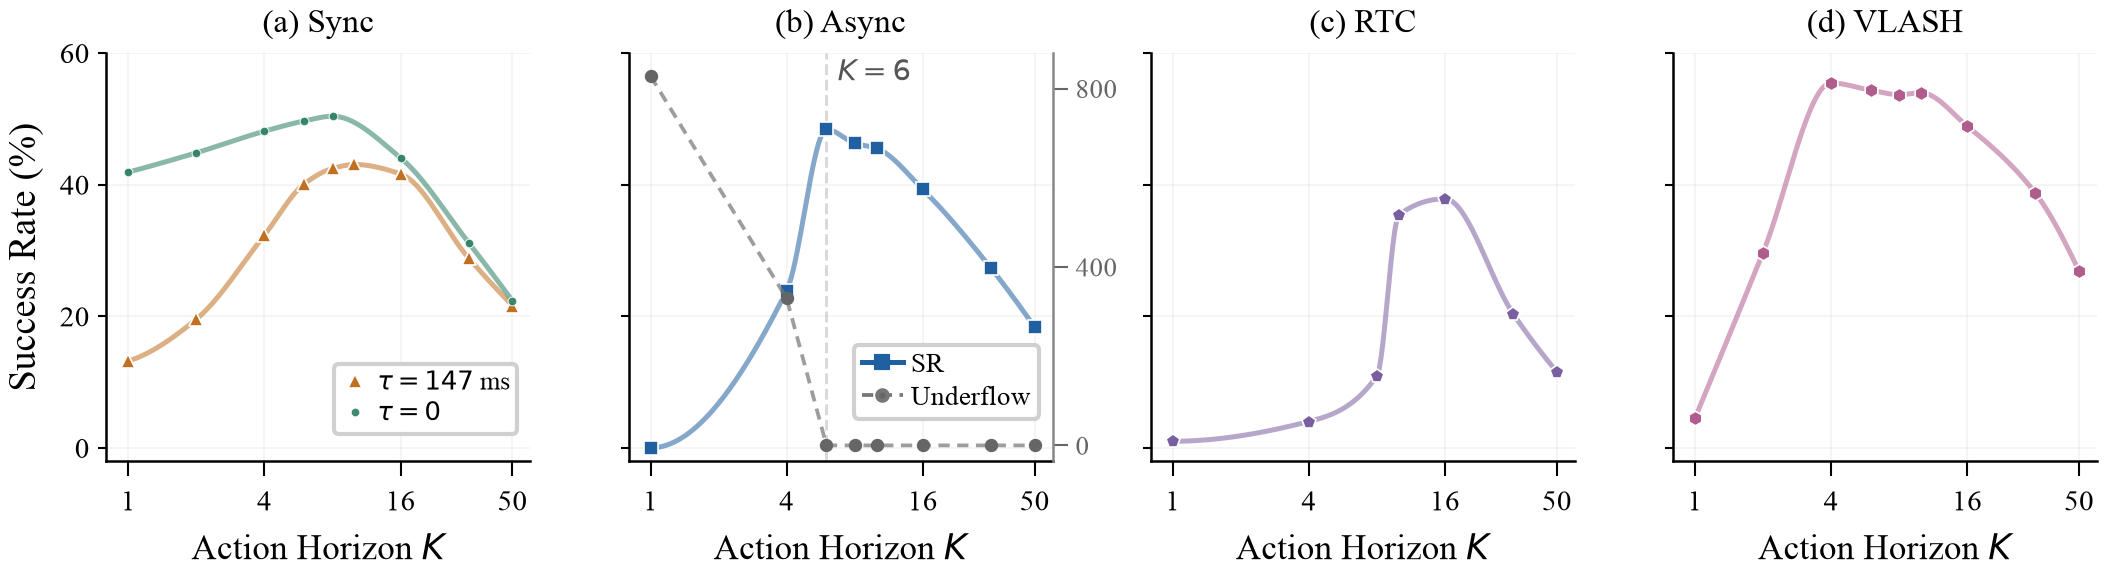
Execution strategies
Timing and queue continuity change dynamic-task performance even when the policy checkpoint is fixed.
Click the figure to enlarge ↗
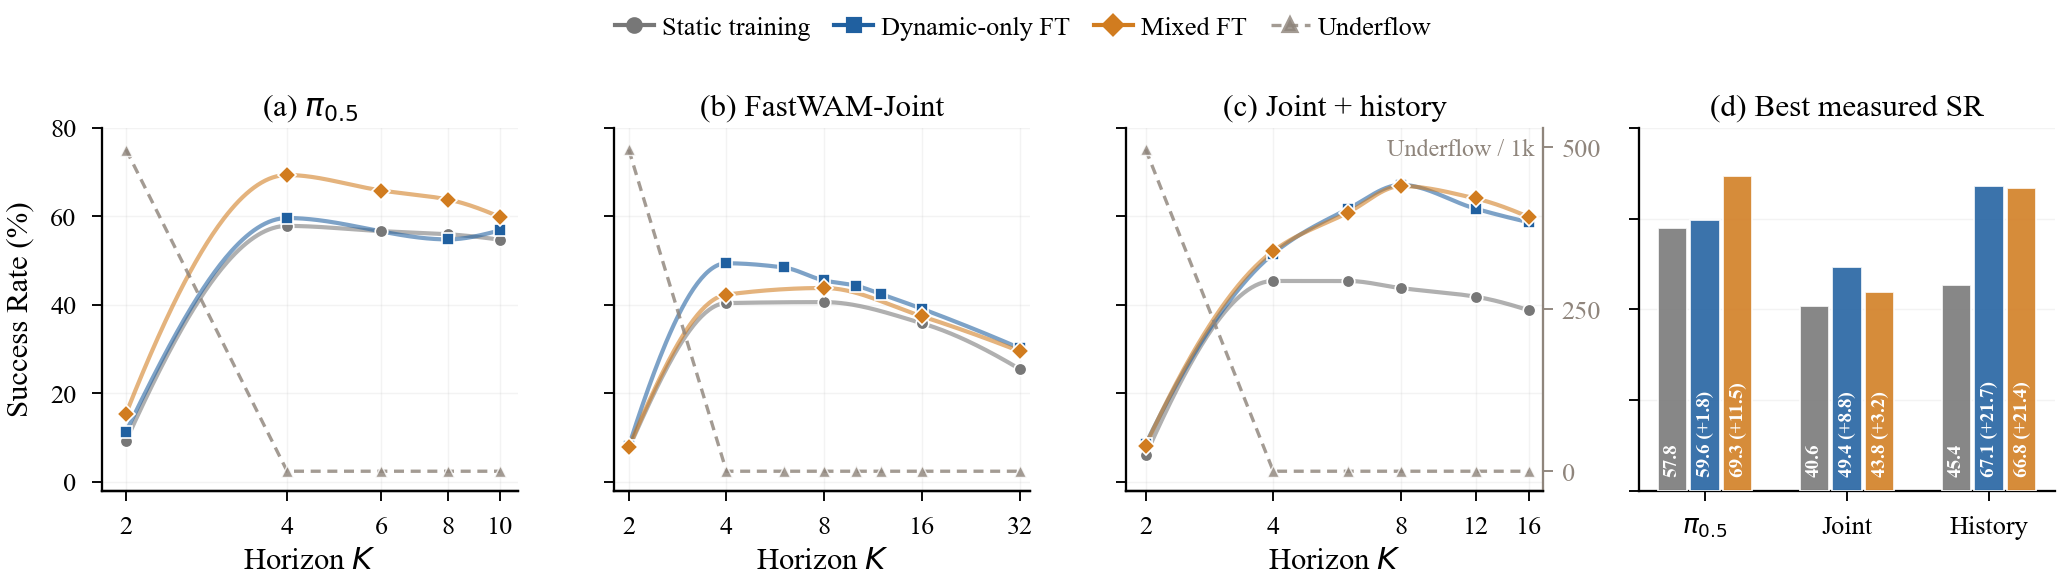
Training with dynamic data
Each evaluated architecture improves under at least one dynamic-data recipe; the gain varies with temporal conditioning and data composition.
Click the figure to enlarge ↗
Aggregate tables are released as CSV files in results/. VLASH uses its own delay-aware checkpoint and is shown as a system reference rather than a same-checkpoint controller ablation.
02 / Benchmark
Explore the 40 tasks
Four LIBERO suites. Three motion patterns. Examples shown at 0.09 m/s.
T01 · Linear
Put both the alphabet soup and the tomato sauce in the basket
Each demonstration combines a manipulation goal with continuous target motion.
03 / Execution
Execution under inference latency
Same task · successful runs · measured latency
Sync
41 hold frames
Model & execution settings
Model
Pi0.5 PyTorch
Latency
147.2 ms (2.94 ticks @ 20 Hz)
Chunk
K = 7
Async
continuous
Model & execution settings
Model
Pi0.5 PyTorch
Latency
147.2 ms (2.94 ticks @ 20 Hz)
Chunk
K = 6
RTC
continuous
Model & execution settings
Model
Pi0.5 PyTorch RTC
Latency
169.8 ms (3.40 ticks @ 20 Hz)
Chunk
K = 16
VLASH
continuous
Model & execution settings
Model
VLASH continuous
Latency
104.0 ms (2.08 ticks @ 20 Hz)
Chunk
K = 5
Sync, Async, and RTC share the same π0.5 task setup. Sync keeps real inference-hold frames. VLASH uses its own model and measured latency.
04 / Adaptation
After dynamic-data fine-tuning
Successful executions · unseen dynamic phases
Dynamic + static fine-tuning
π0.5
success
L10-03 · Turn on the stove and place the moka potAsync · K=4 · 60.3 ms · 0.09 m/s
Dynamic fine-tuning
History FastWAM-Joint
success
Go-02 · Put the bowl on the stoveAsync · K=8 · 89.2 ms · 0.09 m/s